
Tennis Ball-ista 🎾
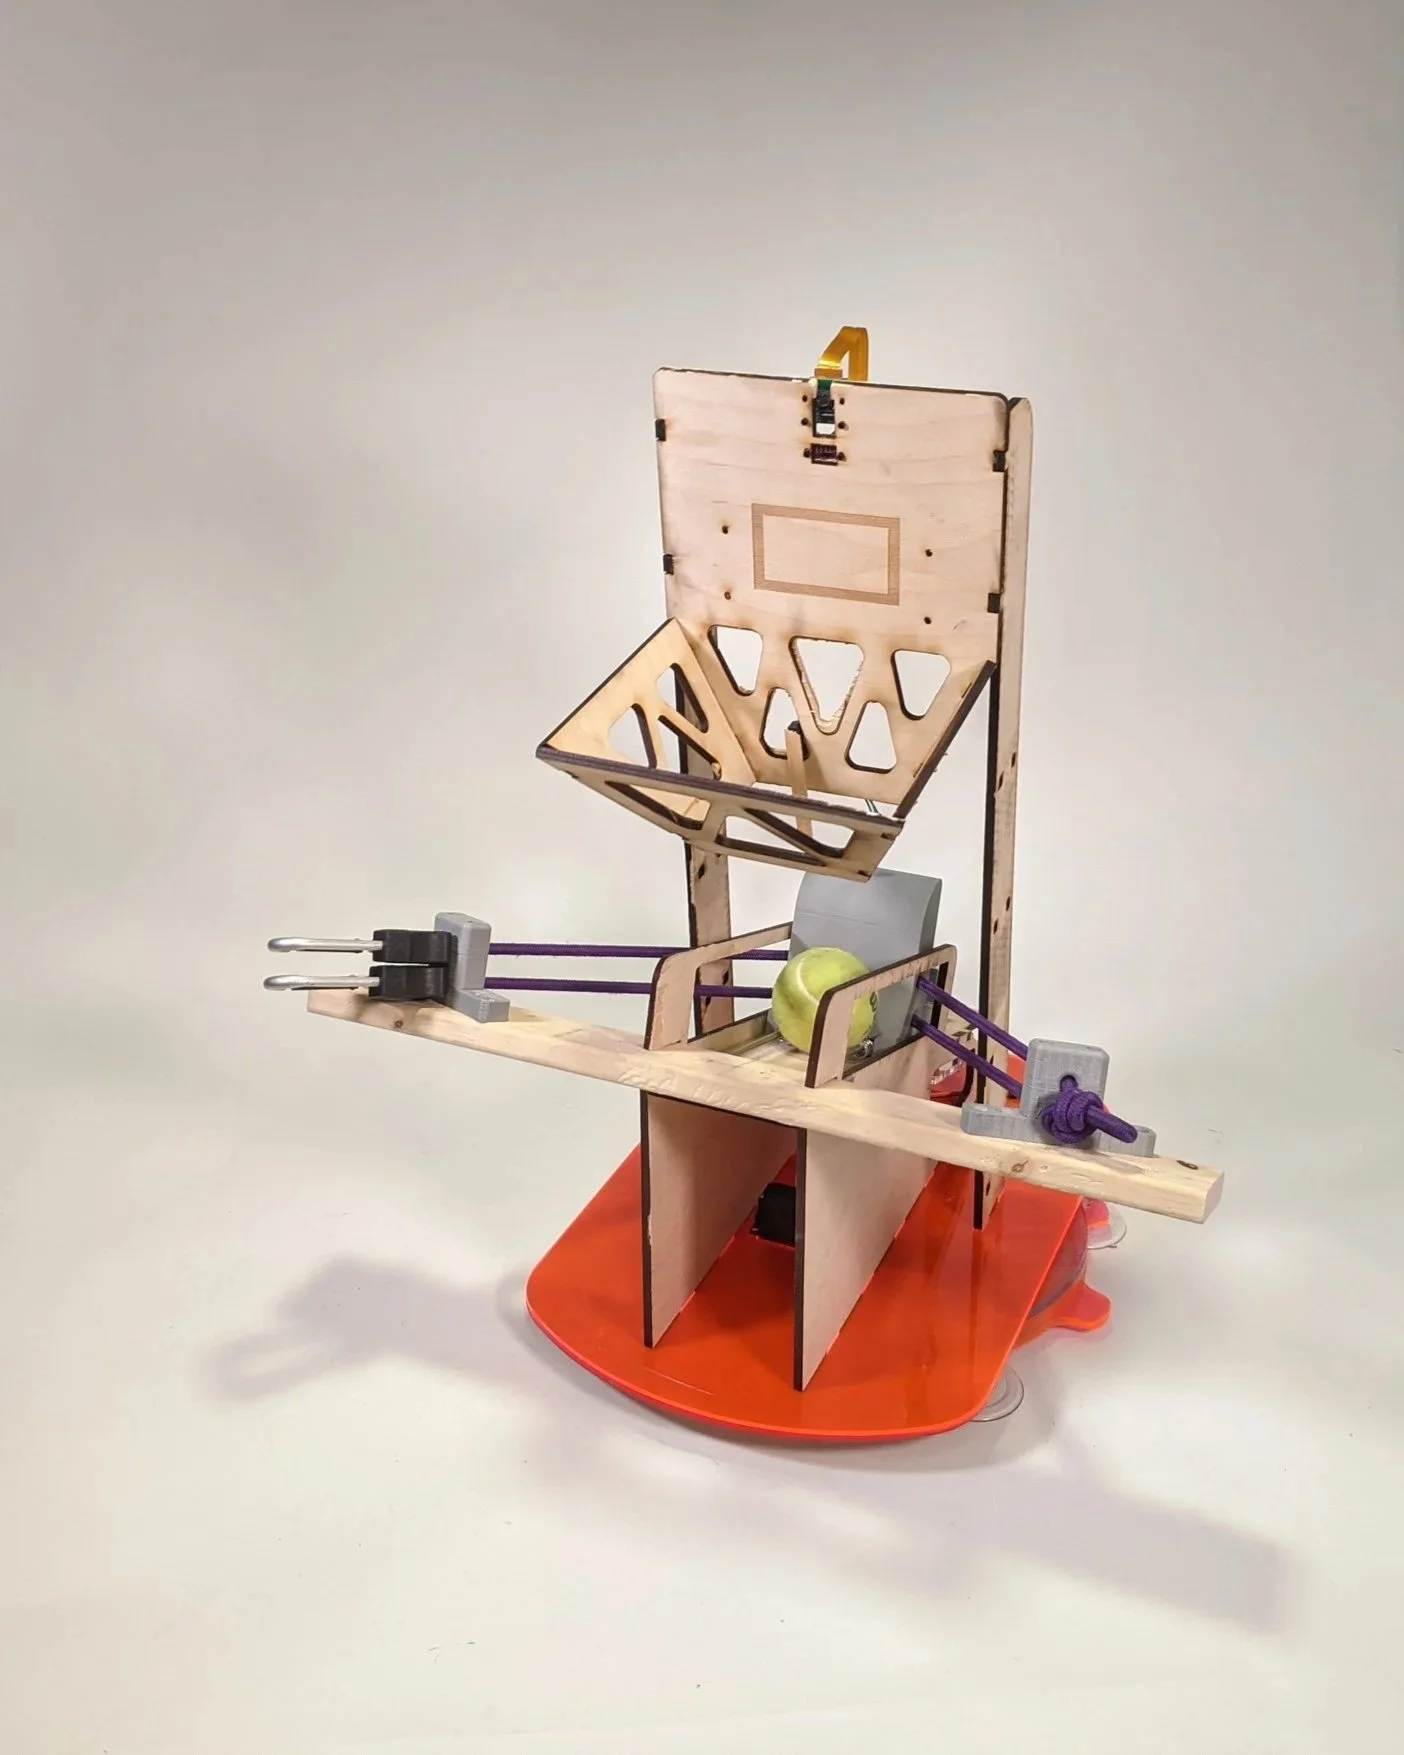
The larger project this existed as part of was a response to the prompt: "make something that can throw and catch a ball". It was a group project for a grad-level robotics course, and the launching mechanism was my contribution.
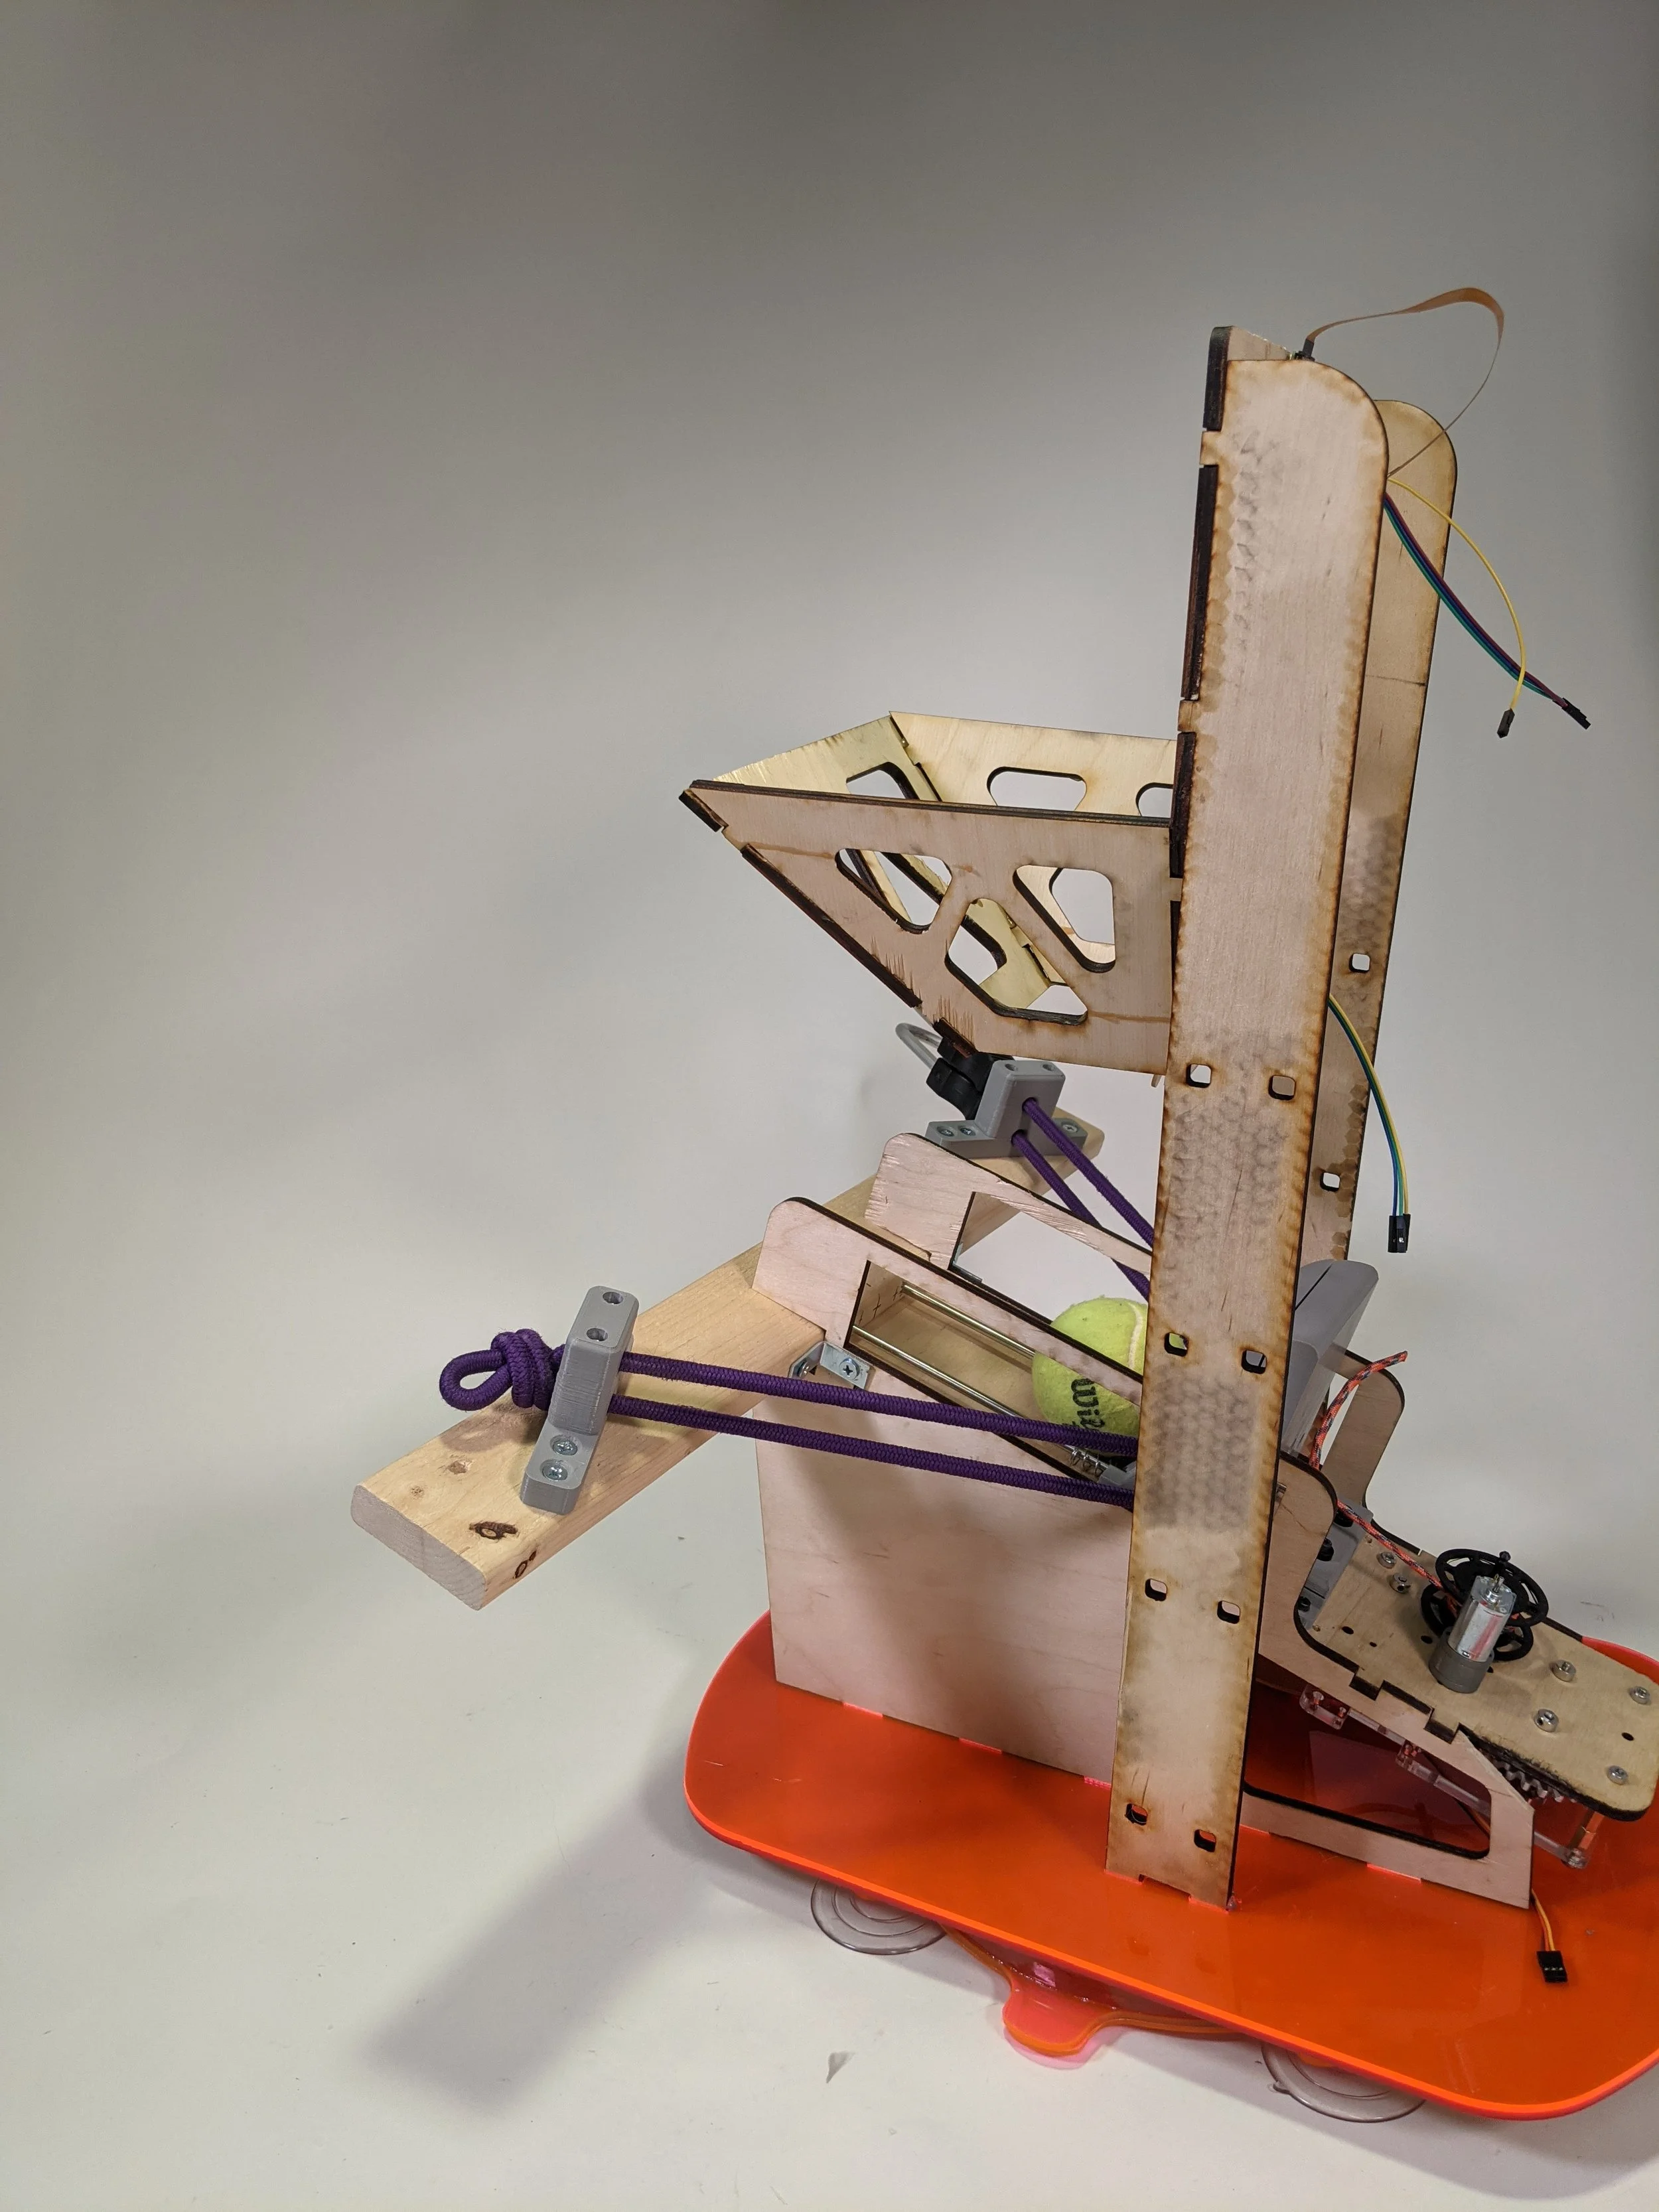
Side view of the larger assembly
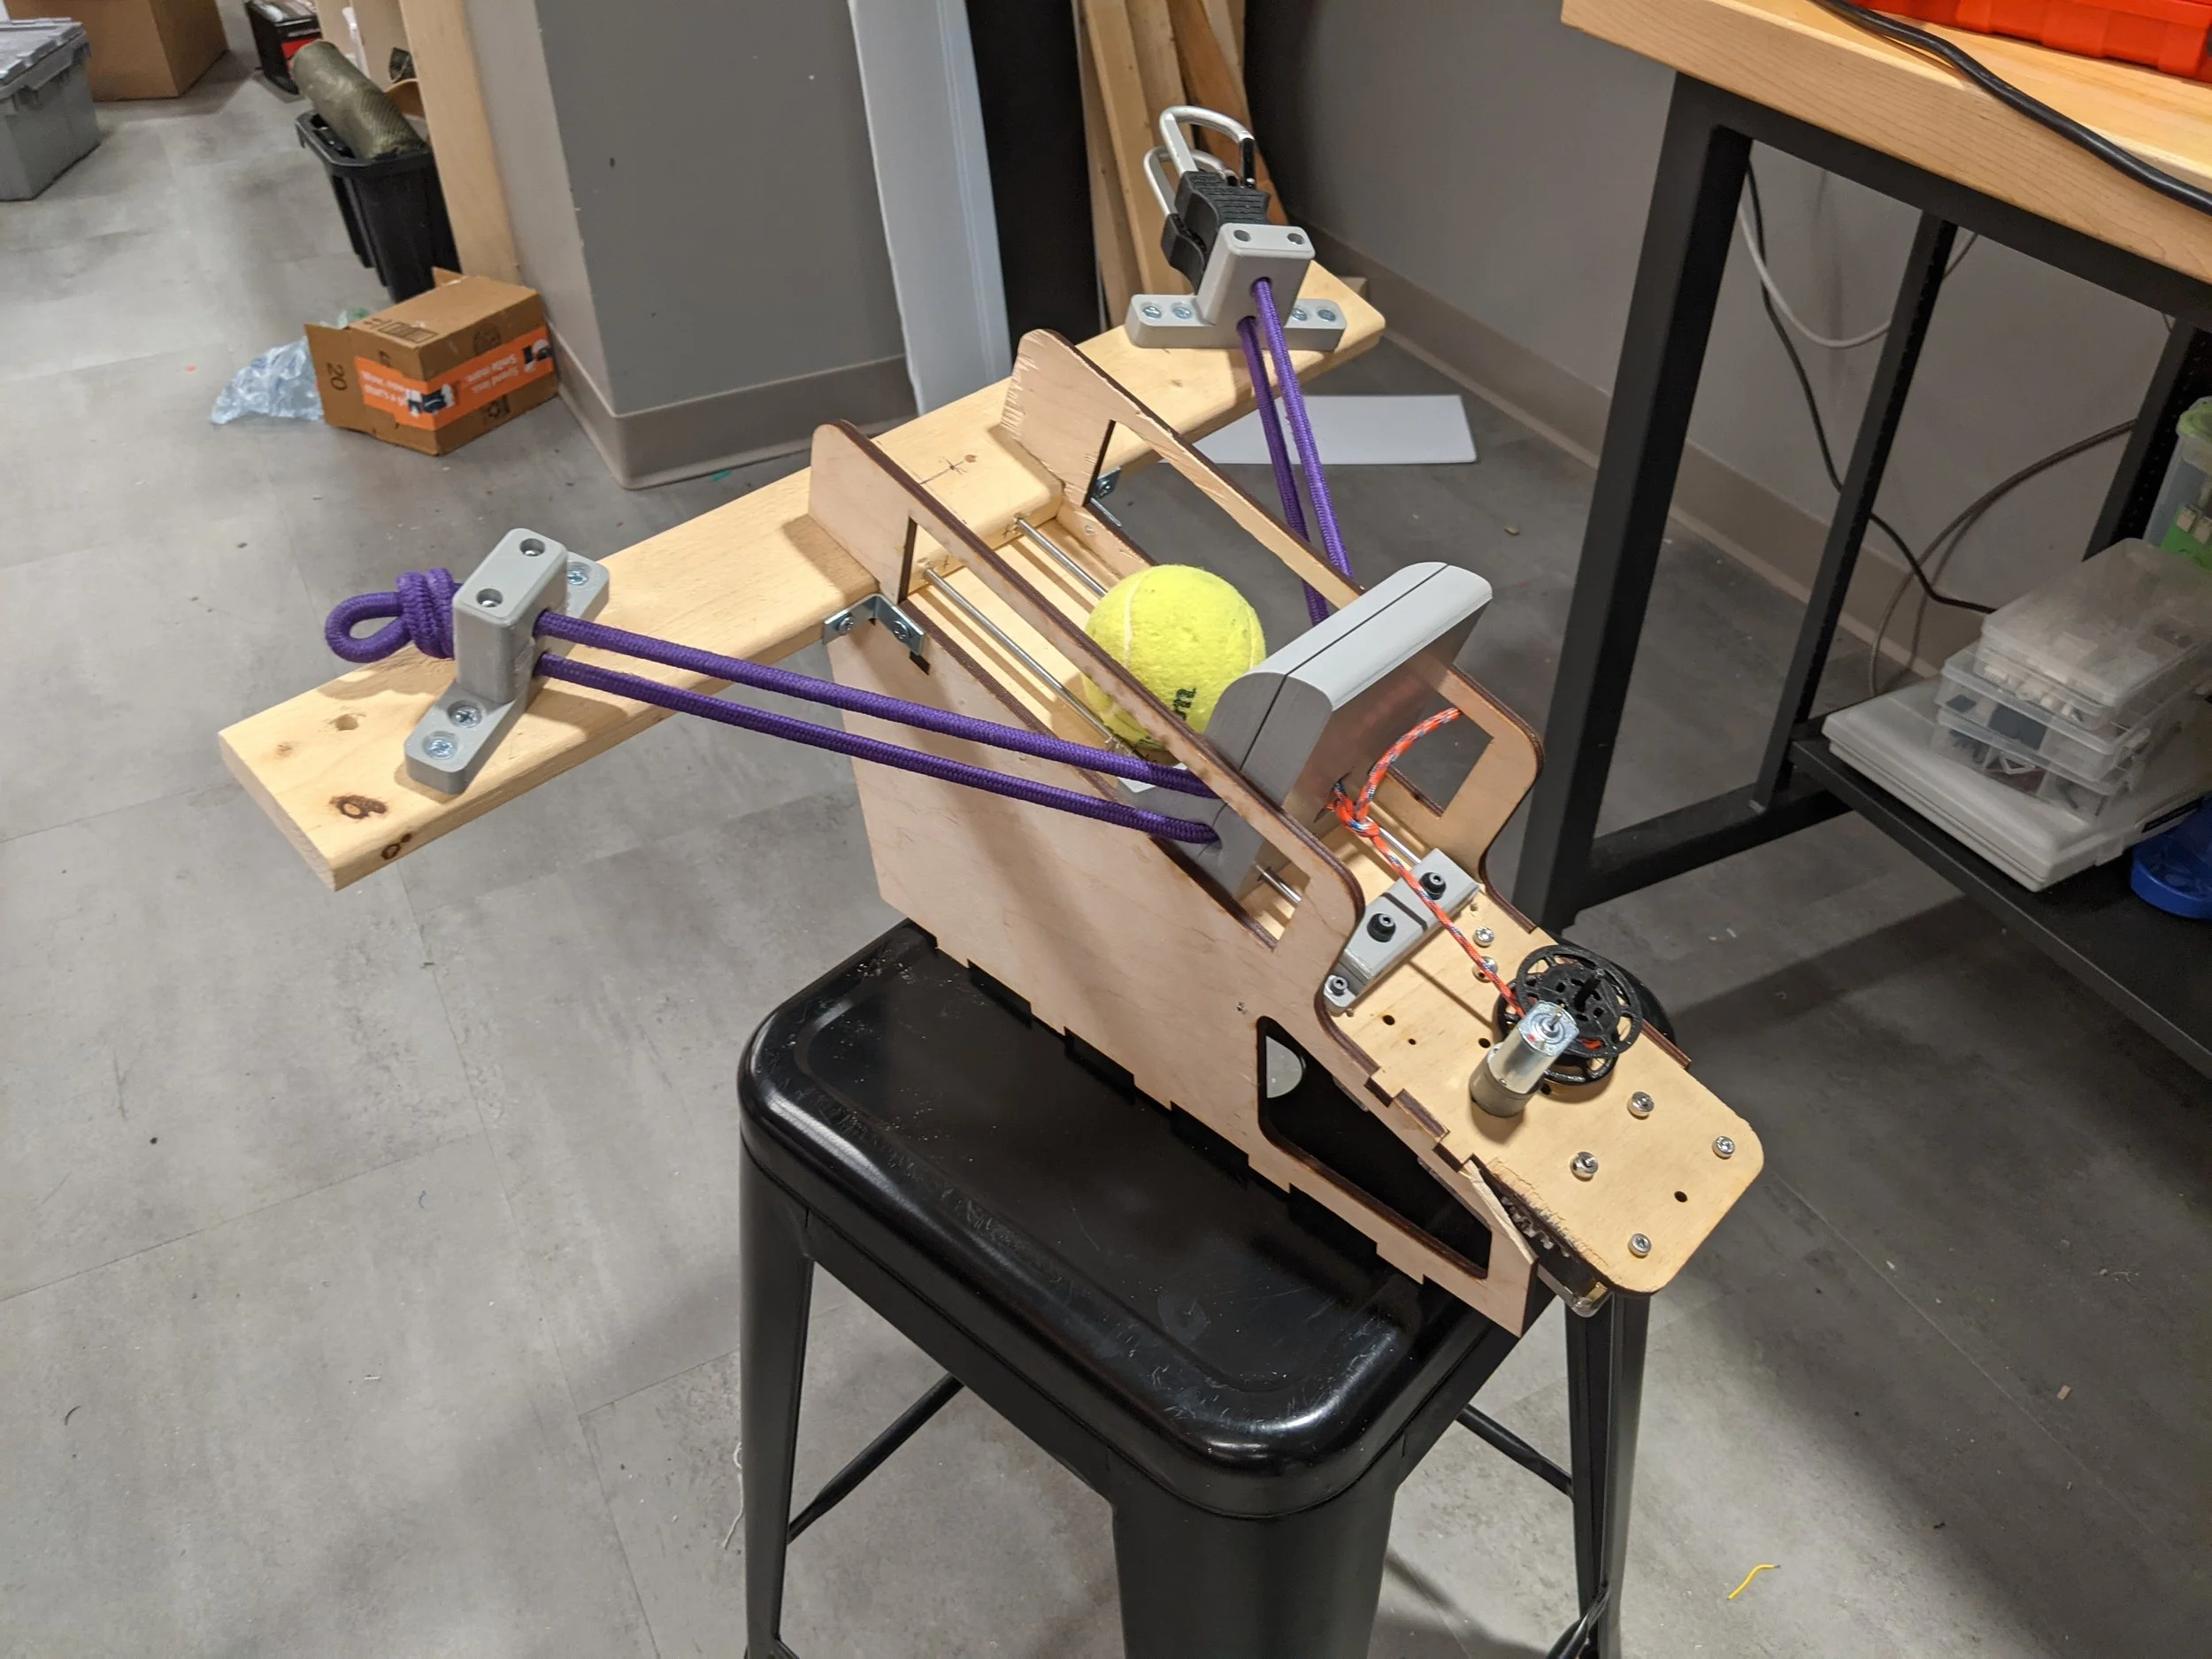
The launching assembly loaded with a tennis ball. Note the non-destructive use of a bungee cord, the multiple 3-D printed parts with heat-set inserts, and "off-label" use of preexisting hardware (including a mismatched allen key as a driveshaft)
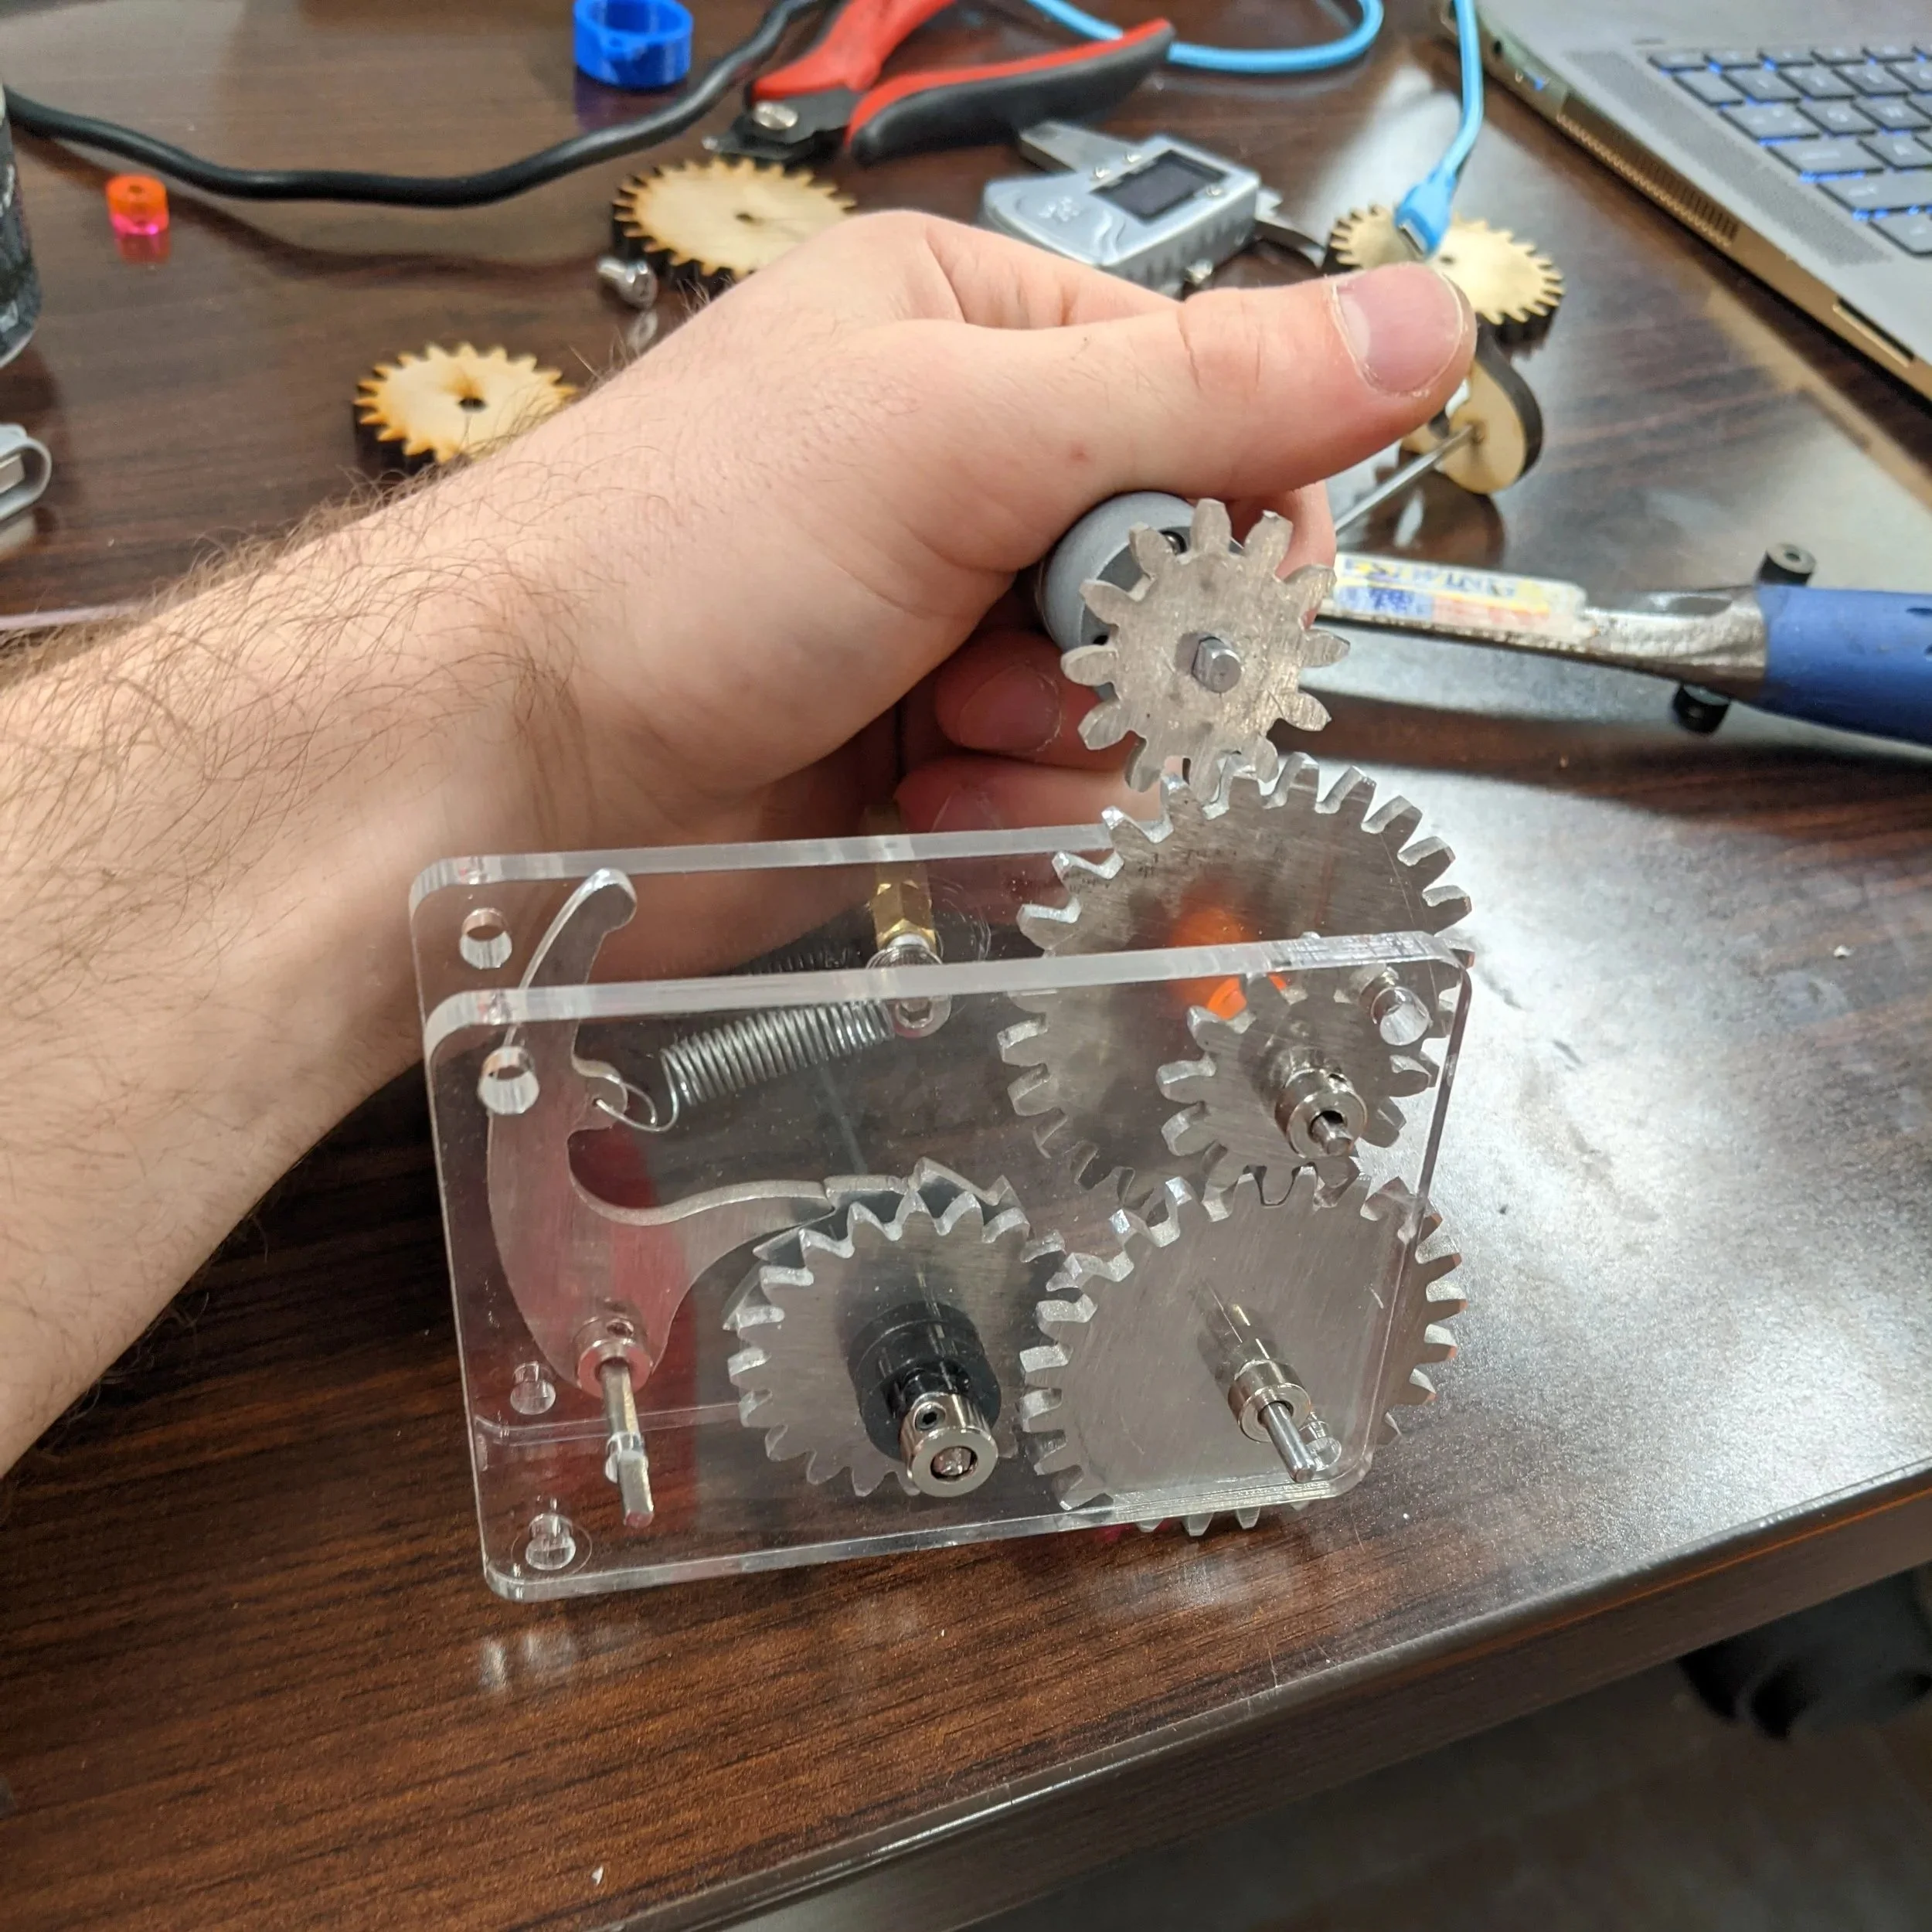
As a first project on our makerspace's new Wazer waterjet, I designed and fabricated an intermittent ratcheting gearbox from scrap aluminum. This allowed the launcher to be loaded under the power of a 24V DC motor and fired by releasing the pawl with a small servo.
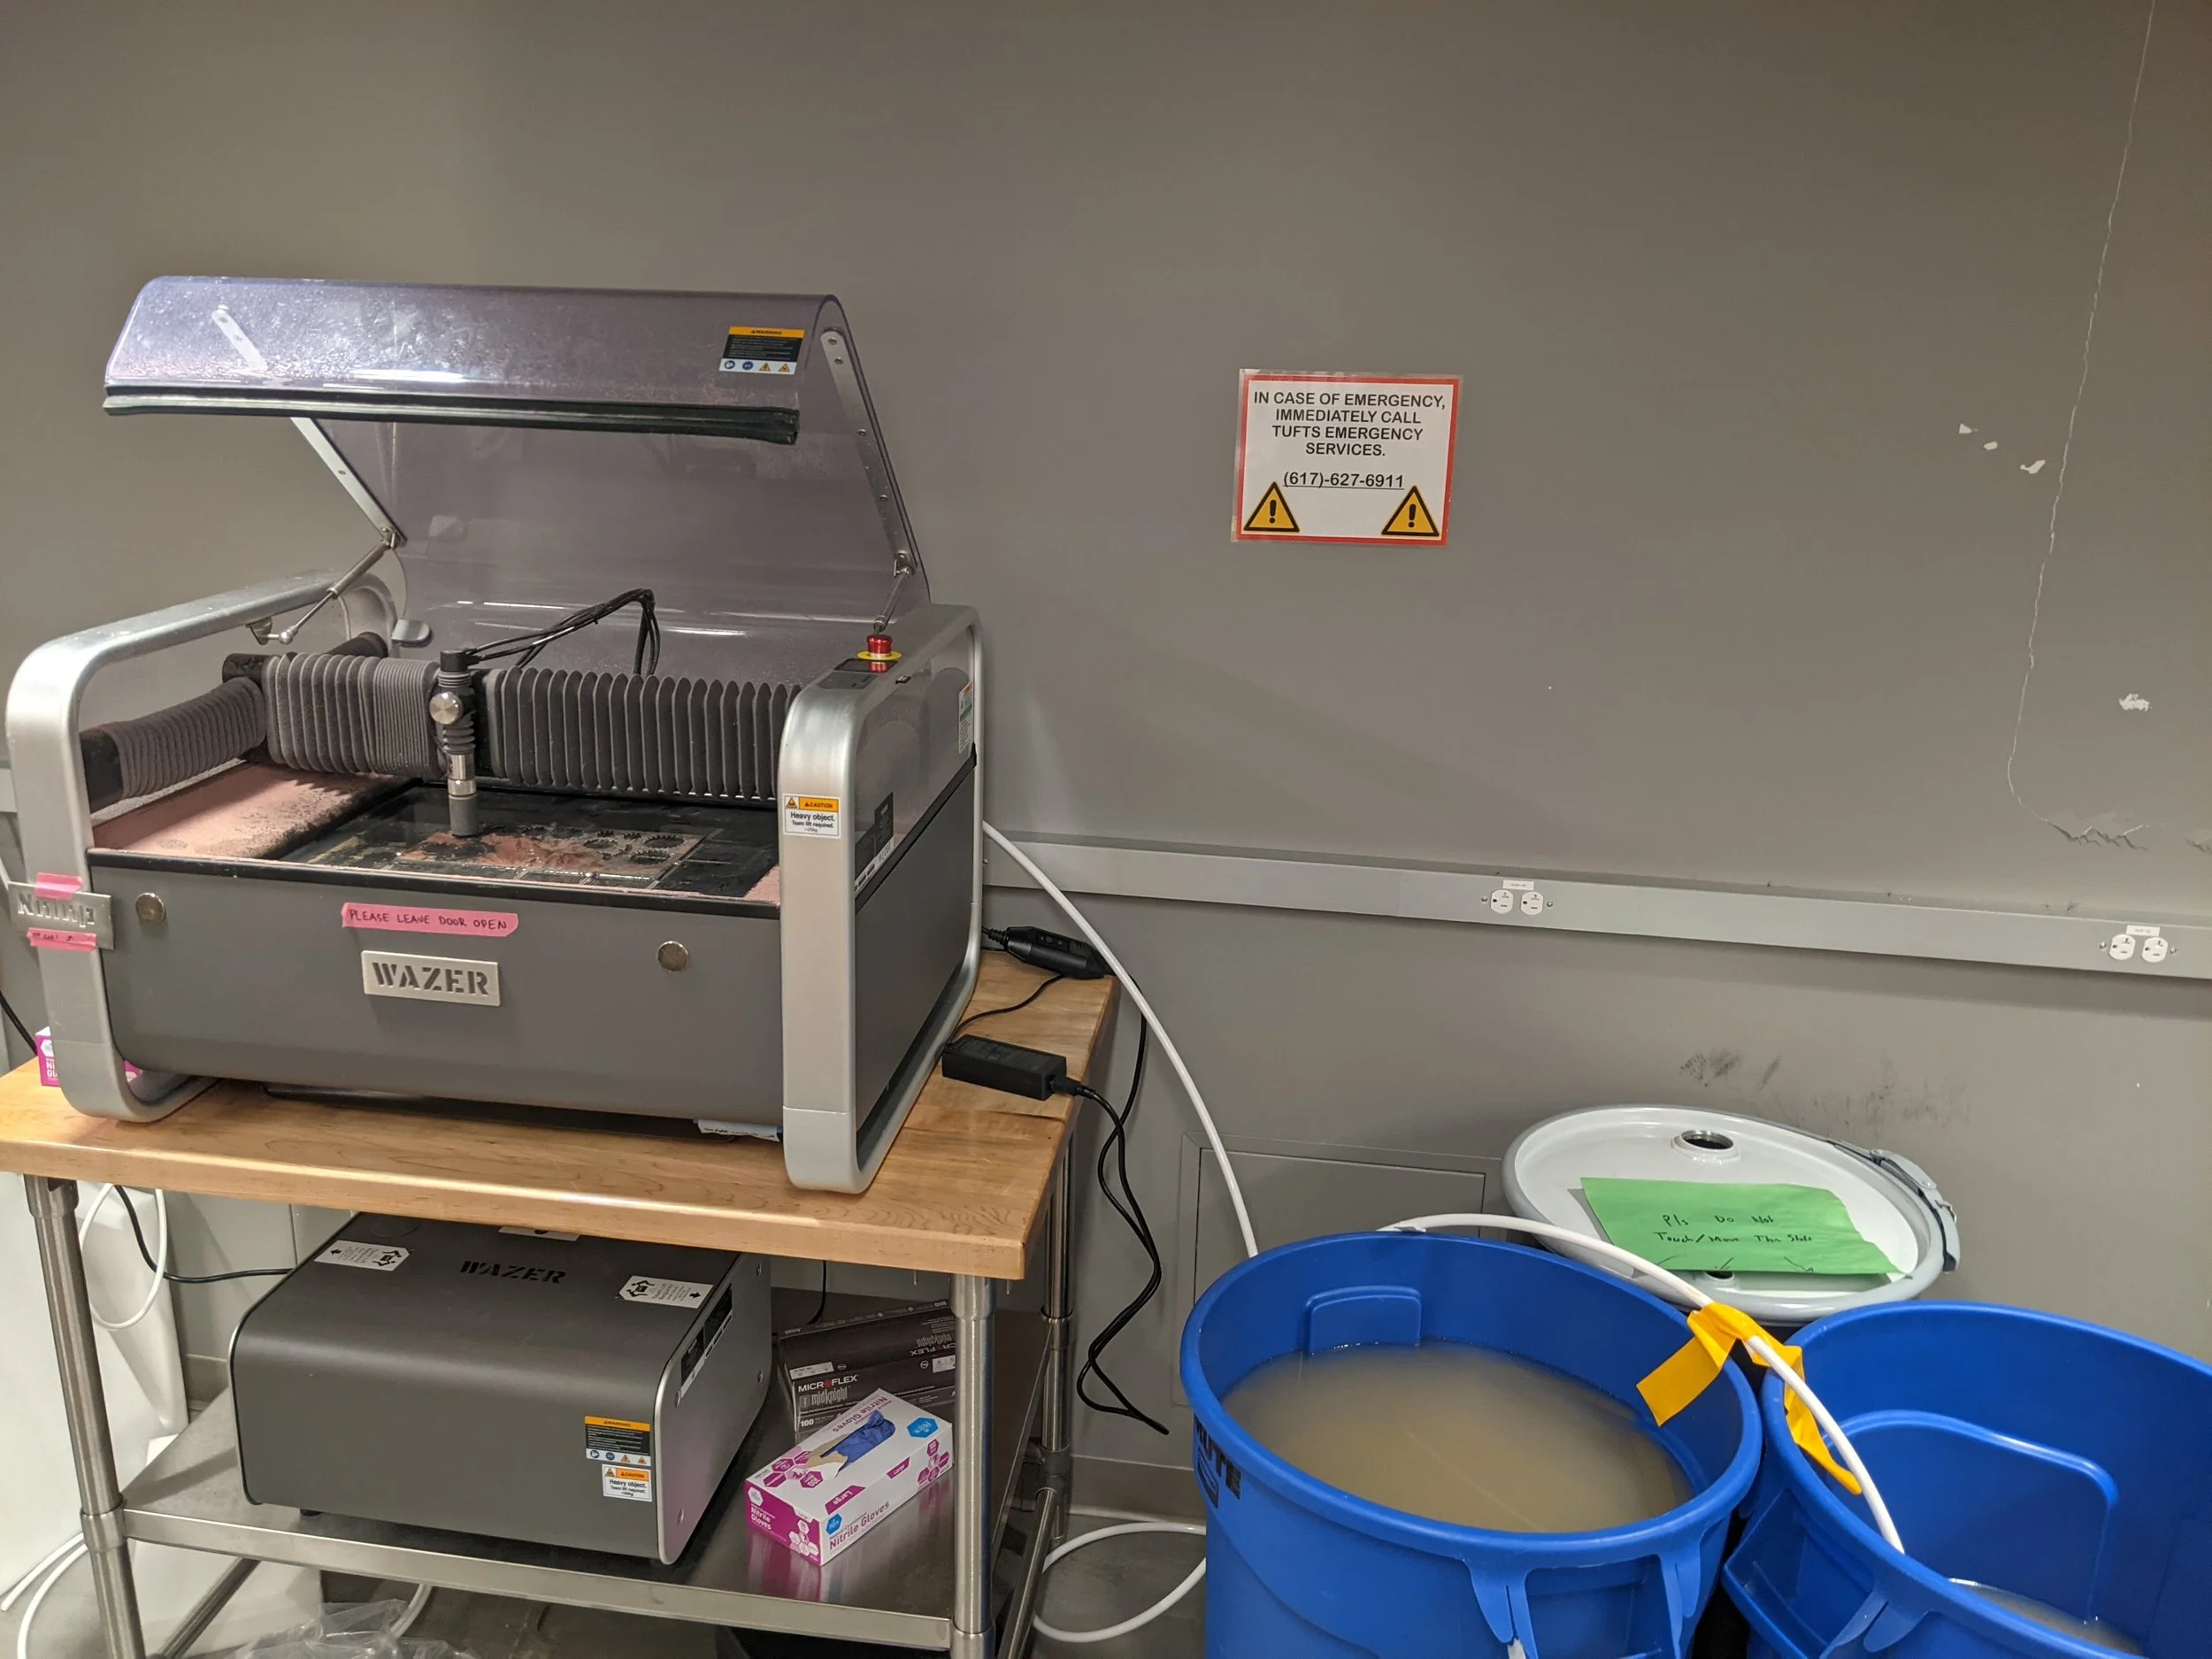
The aforementioned new Wazer desktop waterjet we had just obtained for the makerspace, as well as our janky wastewater setup
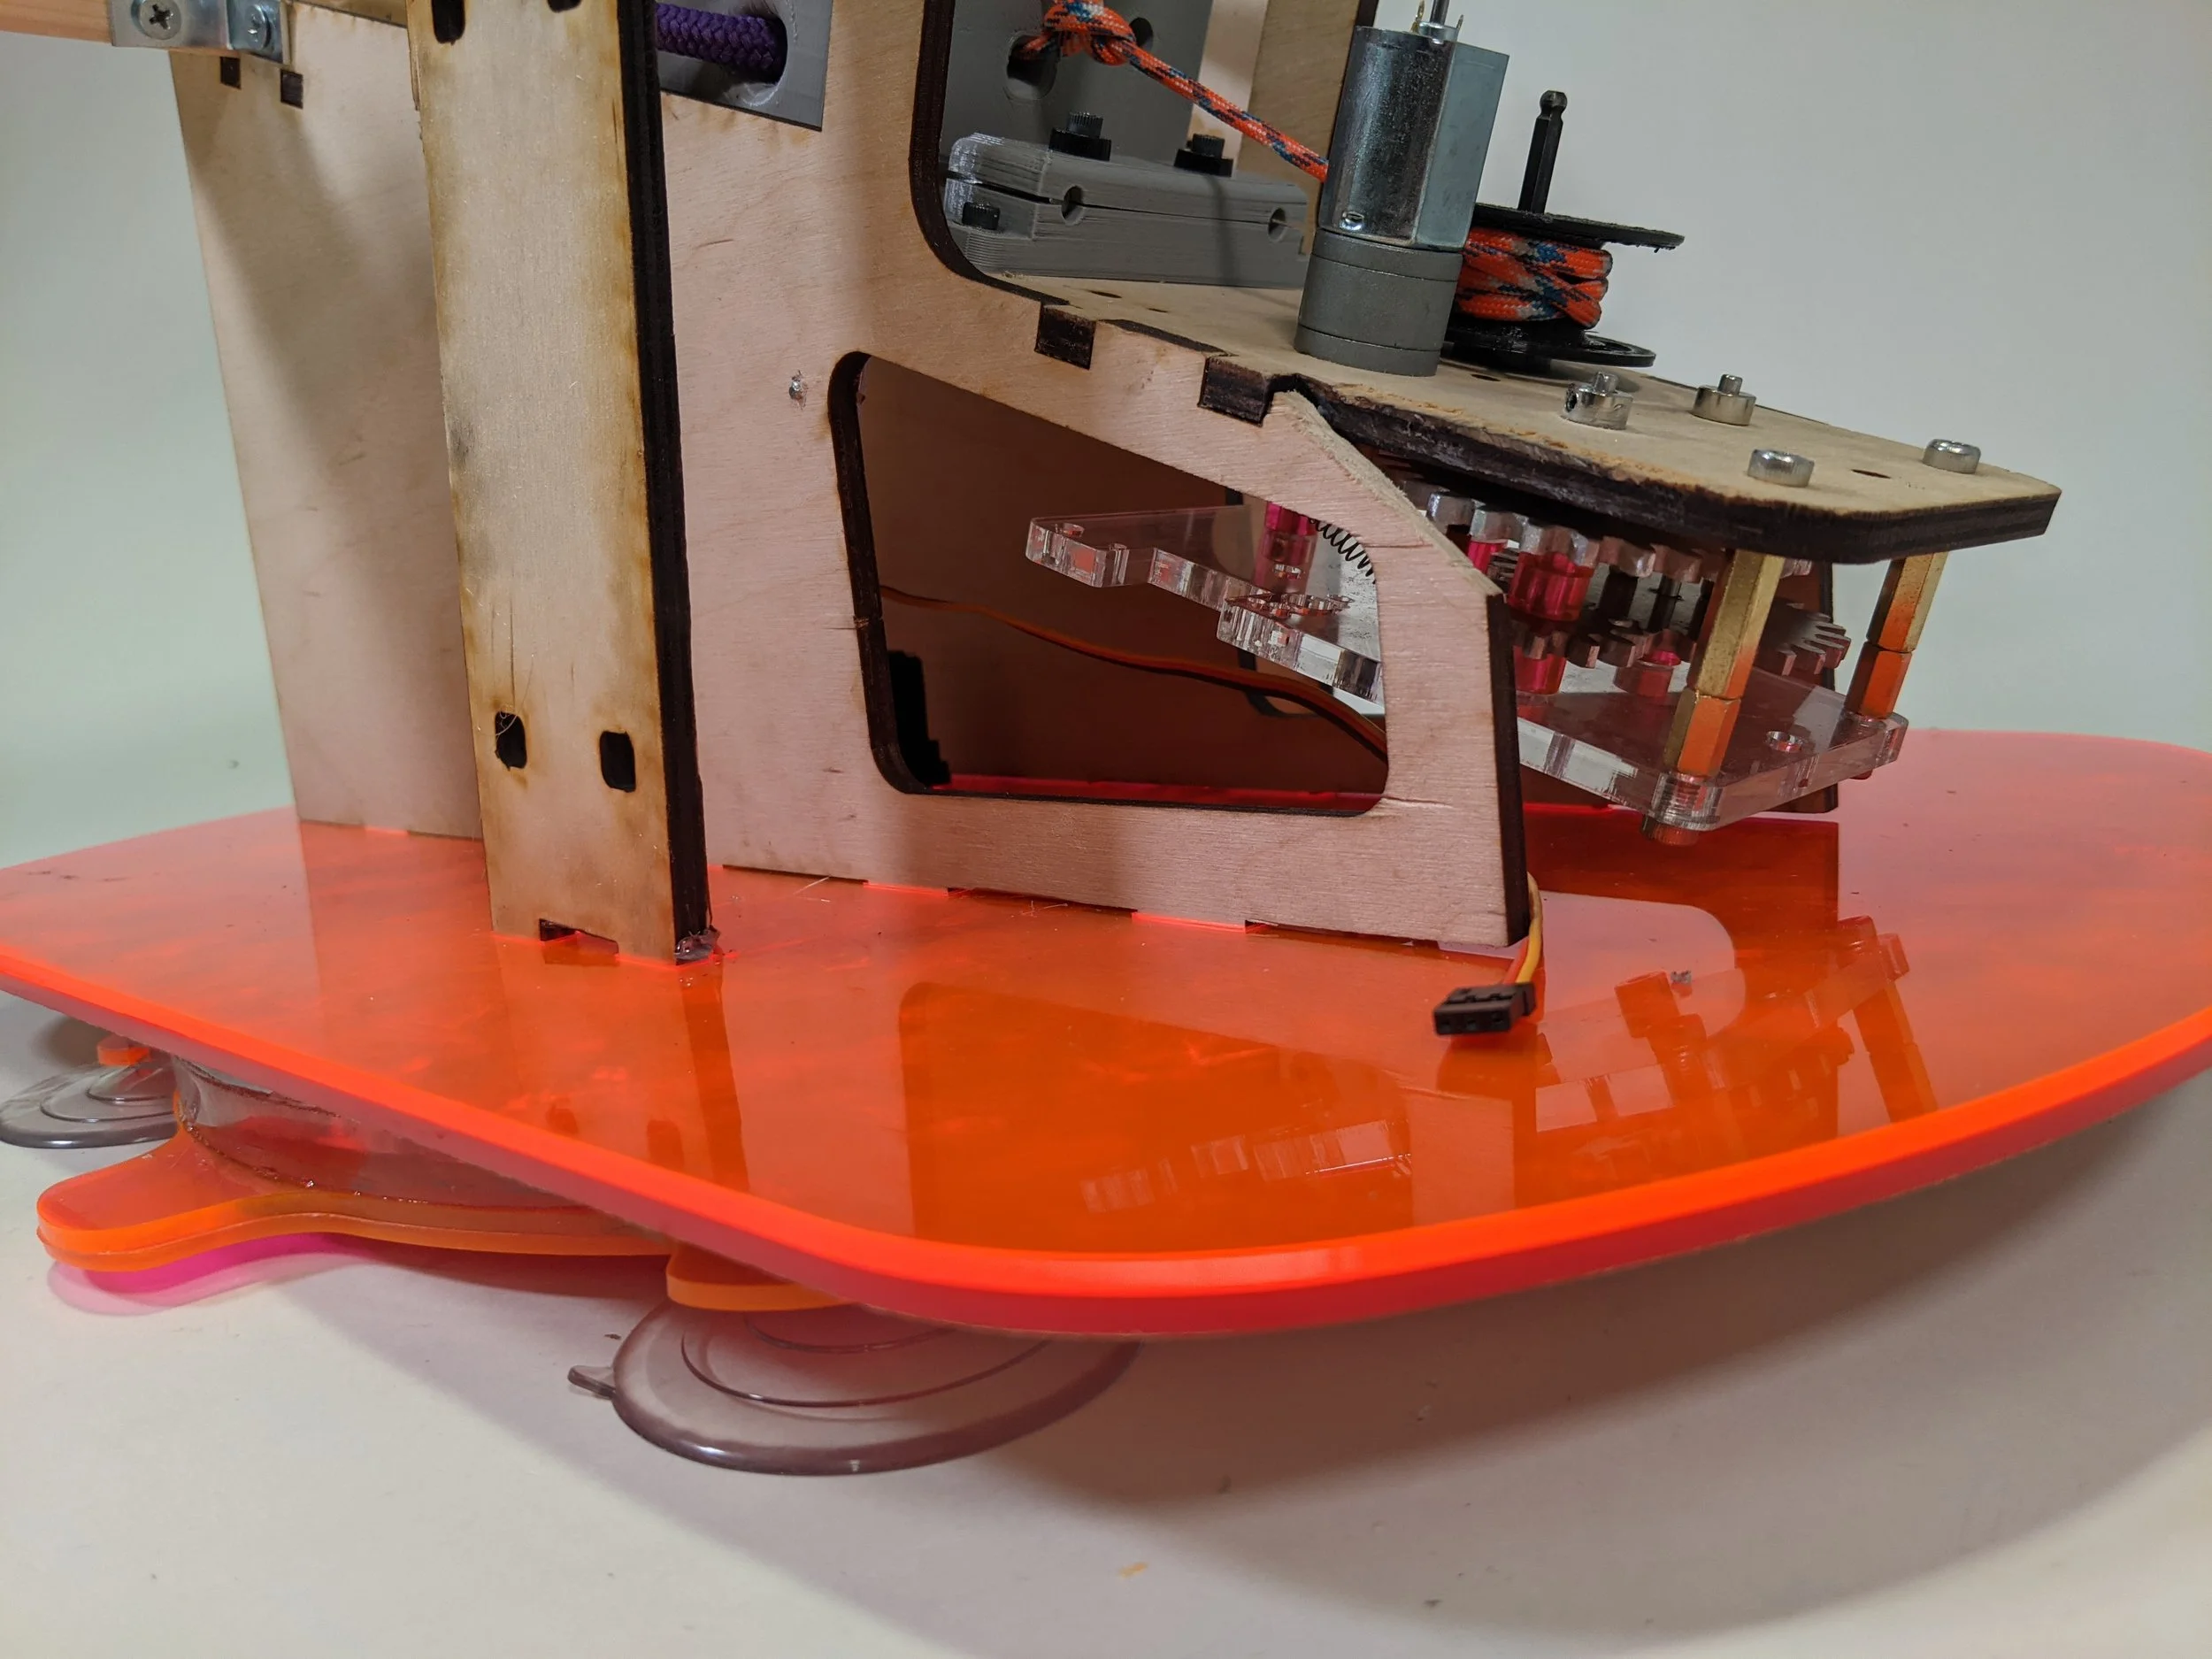
A slightly less obfuscated look at the laser-cut acrylic base, which could be secured to a table using suction cups and be driven to a specific yaw by a 360-degree servo
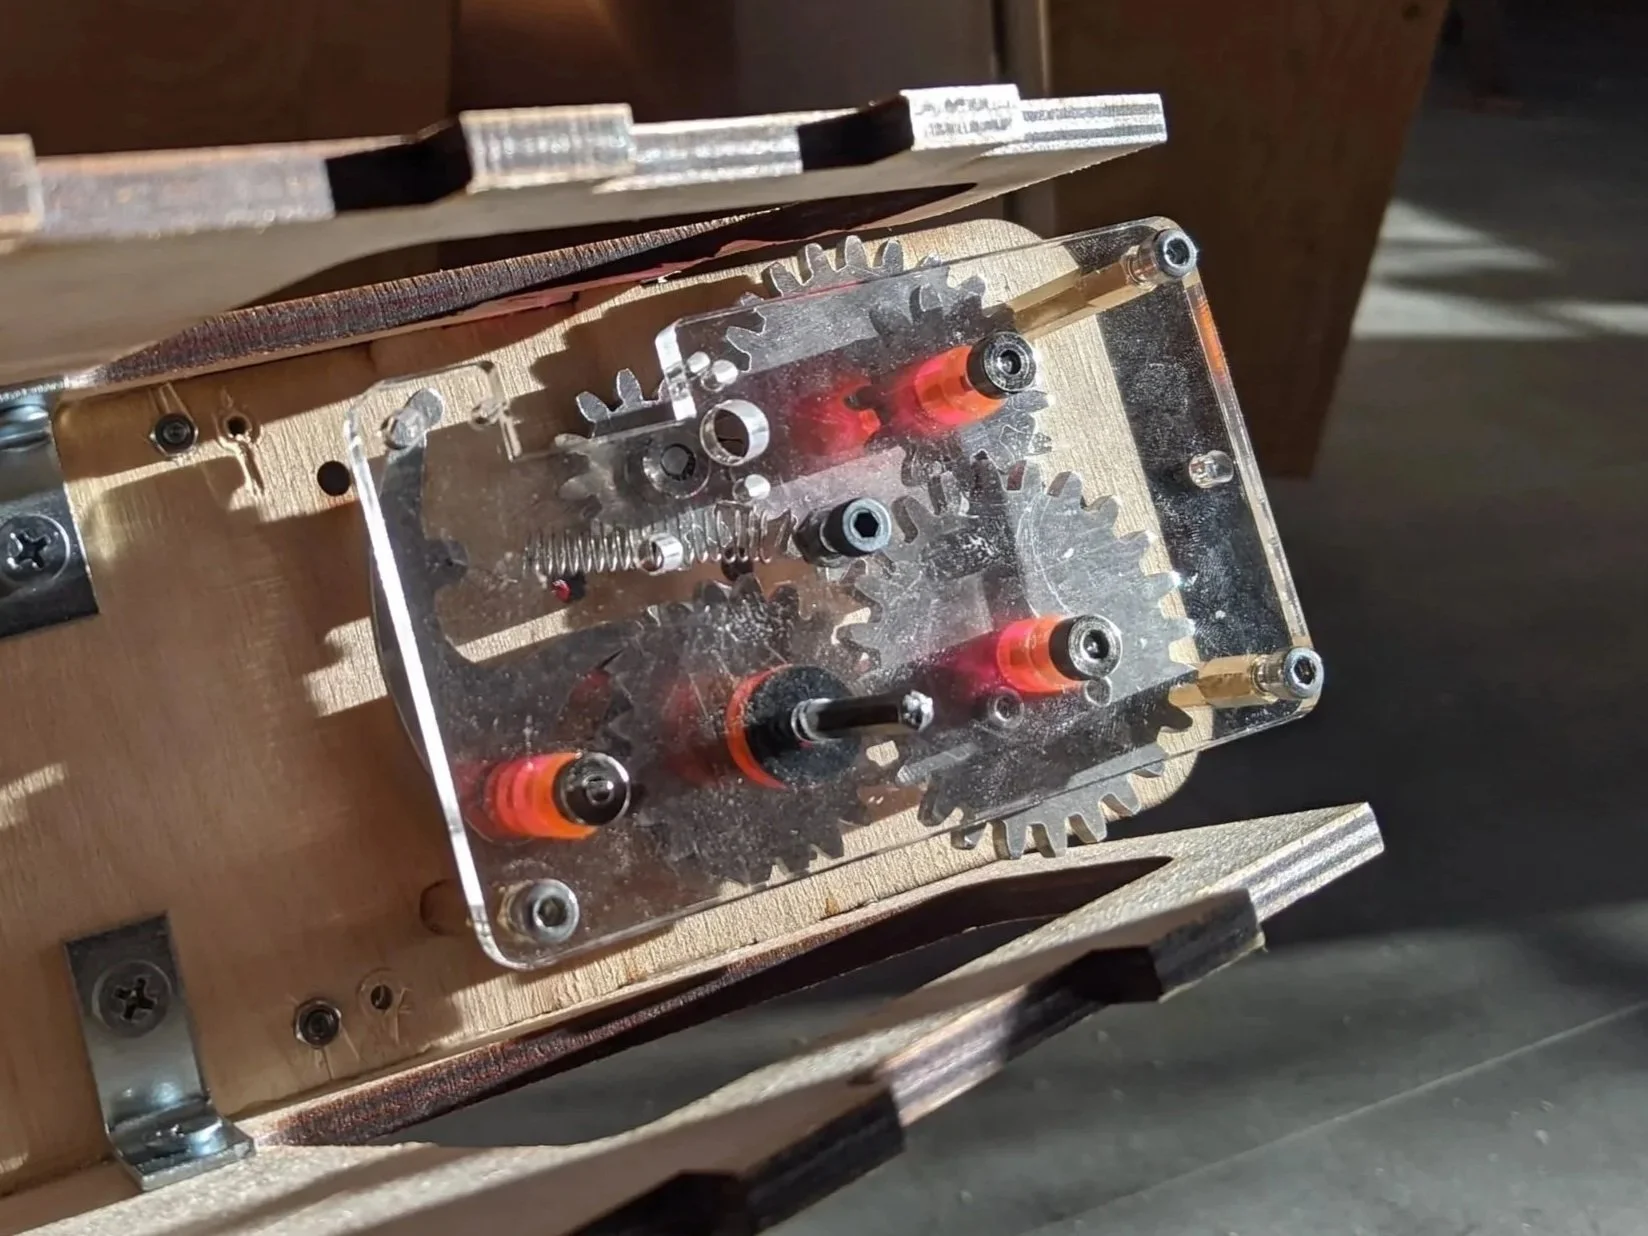
A majestic view of my glorious gearbox, installed and illuminated
Like so many school projects, this 2-week design sprint didn’t yield quite the polished end-product we’d envisioned. Encumbered by exams, final projects, and theses, my classmates and I never quite had the chance to integrate our respective parts into one cohesive device. Incompleteness aside, this remains one of the mechanical engineering projects I’m most proud of.
Check it out in action!
In-class firing test executed by our professor
Isolated unloaded gearbox test with motor running on benchtop DC power supply
First manual pawl-release firing test
“He's going the distance, he's going for speed”